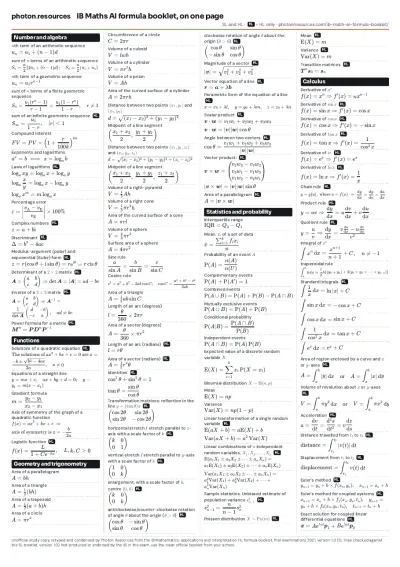
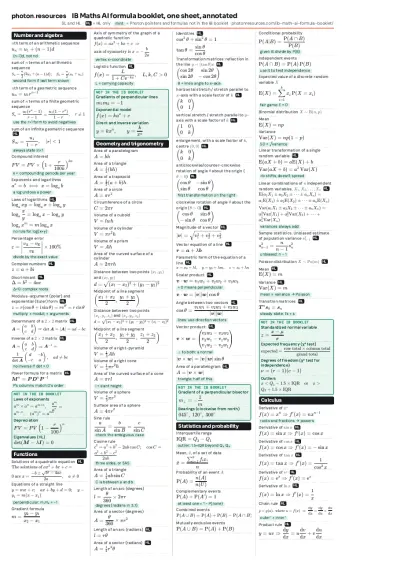
Photon Resources · IB Maths AI formula booklet, annotated · photonresources.com/ib-math-ai-formula-booklet/
Topic 1: Number and algebra
1.2 SL and HL
The nth term of an arithmetic sequence
u_n=u_1+(n-1)dPhoton note(n-1)d, not nd: the first term has had no differences added yet.
The sum of n terms of an arithmetic sequence
S_n=\frac{n}{2}\big(2u_1+(n-1)d\big);\quad S_n=\frac{n}{2}(u_1+u_n)1.3 SL and HL
The nth term of a geometric sequence
u_n=u_1r^{n-1}The sum of n terms of a finite geometric sequence
S_n=\frac{u_1(r^n-1)}{r-1}=\frac{u_1(1-r^n)}{1-r},\quad r\neq11.11 HL only
The sum of an infinite geometric sequence
S_\infty=\frac{u_1}{1-r},\quad |r|<1Photon noteState the condition |r|<1 whenever you use it: it often carries a mark.
1.4 SL and HL
Compound interest
FV=PV\times\left(1+\frac{r}{100k}\right)^{kn}where FV is the future value, PV is the present value, n is the number of years, k is the number of compounding periods per year, r\% is the nominal annual rate of interestPhoton noteOn the calculator's finance solver, money you pay out is negative and money you receive is positive.
1.5 SL and HL
Exponents and logarithms
a^x=b\iff x=\log_abwhere a>0, b>0, a\neq11.9 HL only
Laws of logarithms
\log_axy=\log_ax+\log_ayPhoton noteThere is no rule for \log_a(x+y). Splitting it is a very common lost mark.
1.6 SL and HL
Percentage error
\varepsilon=\left|\frac{v_\text{A}-v_\text{E}}{v_\text{E}}\right|\times100\%where v_\text{E} is the exact value and v_\text{A} is the approximate value of vPhoton noteDivide by the exact value, not the approximate one.
1.12 HL only
Complex numbers
z=a+b\mathrm{i}Discriminant
\Delta=b^2-4acPhoton note\Delta<0 gives two complex conjugate roots.
1.13 HL only
Modulus-argument (polar) and exponential (Euler) form
z=r(\cos\theta+\mathrm{i}\sin\theta)=r\mathrm{e}^{\mathrm{i}\theta}=r\,\mathrm{cis}\,\thetaPhoton noteMultiply: multiply the moduli, add the arguments.
1.14 HL only
Determinant of a 2\times2 matrix
\boldsymbol{A}=\begin{pmatrix}a&b\\c&d\end{pmatrix}\Rightarrow\det\boldsymbol{A}=|\boldsymbol{A}|=ad-bcInverse of a 2\times2 matrix
\boldsymbol{A}=\begin{pmatrix}a&b\\c&d\end{pmatrix}\Rightarrow\boldsymbol{A}^{-1}=\frac{1}{\det\boldsymbol{A}}\begin{pmatrix}d&-b\\-c&a\end{pmatrix},\quad ad\neq bcPhoton noteSwap the leading diagonal, negate the other one. No inverse when the determinant is 0.
1.15 HL only
Power formula for a matrix
\boldsymbol{M}^n=\boldsymbol{P}\boldsymbol{D}^n\boldsymbol{P}^{-1}where \boldsymbol P is the matrix of eigenvectors and \boldsymbol D is the diagonal matrix of eigenvaluesPhoton noteColumns of \boldsymbol P and entries of \boldsymbol D must be in the same order.
Not in the IB booklet · learn or derive these
Depreciation at r\% a year. Loans and annuities go through the calculator's finance solver.
Solve this characteristic equation for \lambda, then find each eigenvector from (\boldsymbol M-\lambda\boldsymbol I)\boldsymbol v=\boldsymbol 0.
Topic 2: Functions
Prior learning HL only
Solutions of a quadratic equation
\text{The solutions of } ax^2+bx+c=0 \text{ are } x=\frac{-b\pm\sqrt{b^2-4ac}}{2a},\quad a\neq02.1 SL and HL
Equations of a straight line
y=mx+c;\quad ax+by+d=0;\quad y-y_1=m(x-x_1)Gradient formula
m=\frac{y_2-y_1}{x_2-x_1}2.5 SL and HL
Axis of symmetry of the graph of a quadratic function
f(x)=ax^2+bx+c\ \Rightarrow\ \text{axis of symmetry is } x=-\frac{b}{2a}Photon noteThe vertex is at x=-\dfrac{b}{2a}; substitute back to get its y-coordinate.
2.9 HL only
Logistic function
f(x)=\frac{L}{1+C\mathrm{e}^{-kx}},\quad L,k,C>0Photon noteL is the carrying capacity: the horizontal asymptote the model levels off at.
Not in the IB booklet · learn or derive these
Needed for perpendicular bisectors in Voronoi diagrams.
c is the horizontal asymptote. Growth if a>1, decay if 0<a<1.
Topic 3: Geometry and trigonometry
Prior learning SL and HL
Area of a parallelogram
A=bhwhere b is the base, h is the heightArea of a triangle
A=\tfrac{1}{2}(bh)where b is the base, h is the heightArea of a trapezoid
A=\tfrac{1}{2}(a+b)hwhere a and b are the parallel sides, h is the heightArea of a circle
A=\pi r^2where r is the radiusCircumference of a circle
C=2\pi rwhere r is the radiusVolume of a cuboid
V=lwhwhere l is the length, w is the width, h is the heightVolume of a cylinder
V=\pi r^2hwhere r is the radius, h is the heightVolume of a prism
V=Ahwhere A is the area of cross-section, h is the heightArea of the curved surface of a cylinder
A=2\pi rhwhere r is the radius, h is the heightPhoton noteTotal surface area of a closed cylinder adds the two ends: 2\pi rh+2\pi r^2.
Distance between two points (x_1,y_1) and (x_2,y_2)
d=\sqrt{(x_1-x_2)^2+(y_1-y_2)^2}Coordinates of the midpoint of a line segment with endpoints (x_1,y_1) and (x_2,y_2)
\left(\frac{x_1+x_2}{2},\ \frac{y_1+y_2}{2}\right)3.1 SL and HL
Distance between two points (x_1,y_1,z_1) and (x_2,y_2,z_2)
d=\sqrt{(x_1-x_2)^2+(y_1-y_2)^2+(z_1-z_2)^2}Coordinates of the midpoint of a line segment with endpoints (x_1,y_1,z_1) and (x_2,y_2,z_2)
\left(\frac{x_1+x_2}{2},\ \frac{y_1+y_2}{2},\ \frac{z_1+z_2}{2}\right)Volume of a right-pyramid
V=\tfrac{1}{3}Ahwhere A is the area of the base, h is the heightVolume of a right cone
V=\tfrac{1}{3}\pi r^2hwhere r is the radius, h is the heightArea of the curved surface of a cone
A=\pi rlwhere r is the radius, l is the slant heightPhoton notel is the slant height, not the vertical height. Find it with Pythagoras: l=\sqrt{r^2+h^2}.
Volume of a sphere
V=\tfrac{4}{3}\pi r^3where r is the radiusSurface area of a sphere
A=4\pi r^2where r is the radiusPhoton noteA hemisphere's curved surface is 2\pi r^2; add \pi r^2 if it has a flat base.
3.2 SL and HL
Sine rule
\frac{a}{\sin A}=\frac{b}{\sin B}=\frac{c}{\sin C}Photon noteGiven two sides and a non-included angle, check for a second (obtuse) solution: the ambiguous case.
Cosine rule
c^2=a^2+b^2-2ab\cos C;\quad \cos C=\frac{a^2+b^2-c^2}{2ab}Photon noteUse it for three sides, or two sides and the angle between them.
Area of a triangle
A=\tfrac{1}{2}ab\sin CPhoton noteC is the angle between sides a and b.
3.4 SL and HL
Length of an arc
l=\frac{\theta}{360}\times2\pi rwhere \theta is the angle measured in degrees, r is the radiusArea of a sector
A=\frac{\theta}{360}\times\pi r^2where \theta is the angle measured in degrees, r is the radiusPhoton noteSL uses degrees here; HL adds the radian versions in 3.7.
3.7 HL only
Length of an arc
l=r\thetawhere r is the radius, \theta is the angle measured in radiansArea of a sector
A=\tfrac{1}{2}r^2\thetawhere r is the radius, \theta is the angle measured in radians3.8 HL only
Identities
\cos^2\theta+\sin^2\theta=13.9 HL only
Transformation matrices
\begin{pmatrix}\cos2\theta&\sin2\theta\\\sin2\theta&-\cos2\theta\end{pmatrix}reflection in the line y=(\tan\theta)xPhoton noteUse \theta, the angle the line makes with the x-axis; the matrix doubles it for you.
Photon noteFor “A then B”, multiply \boldsymbol{BA}: the first transformation goes on the right. Area scales by |\det|.
3.10 HL only
Magnitude of a vector
|\boldsymbol{v}|=\sqrt{v_1^2+v_2^2+v_3^2}where \boldsymbol v=\begin{pmatrix}v_1\\v_2\\v_3\end{pmatrix}3.11 HL only
Vector equation of a line
\boldsymbol{r}=\boldsymbol{a}+\lambda\boldsymbol{b}Photon noteIn kinematics questions, \boldsymbol b is the velocity and \lambda is time.
Parametric form of the equation of a line
x=x_0+\lambda l,\quad y=y_0+\lambda m,\quad z=z_0+\lambda n3.13 HL only
Scalar product
\boldsymbol{v}\cdot\boldsymbol{w}=v_1w_1+v_2w_2+v_3w_3where \boldsymbol v=\begin{pmatrix}v_1\\v_2\\v_3\end{pmatrix}, \boldsymbol w=\begin{pmatrix}w_1\\w_2\\w_3\end{pmatrix}Photon notePerpendicular vectors have \boldsymbol v\cdot\boldsymbol w=0.
Angle between two vectors
\cos\theta=\frac{v_1w_1+v_2w_2+v_3w_3}{|\boldsymbol{v}||\boldsymbol{w}|}Photon noteFor the angle between two lines, use their direction vectors. Take the acute angle unless told otherwise.
Vector product
\boldsymbol{v}\times\boldsymbol{w}=\begin{pmatrix}v_2w_3-v_3w_2\\v_3w_1-v_1w_3\\v_1w_2-v_2w_1\end{pmatrix}where \boldsymbol v=\begin{pmatrix}v_1\\v_2\\v_3\end{pmatrix}, \boldsymbol w=\begin{pmatrix}w_1\\w_2\\w_3\end{pmatrix}Photon noteThe result is perpendicular to both \boldsymbol v and \boldsymbol w: the quickest way to find a normal.
Area of a parallelogram
A=|\boldsymbol{v}\times\boldsymbol{w}|where \boldsymbol v and \boldsymbol w form two adjacent sides of a parallelogramPhoton noteA triangle with these two sides has half this area.
Not in the IB booklet · learn or derive these
Through the midpoint of the two sites. This builds every Voronoi edge.
Always three figures: 045°, not 45°.
Topic 4: Statistics and probability
4.2 SL and HL
Interquartile range
\text{IQR}=Q_3-Q_1Photon noteAn outlier is more than 1.5\times\text{IQR} below Q_1 or above Q_3.
4.3 SL and HL
Mean, \bar x, of a set of data
\bar x=\frac{\sum_{i=1}^{k}f_ix_i}{n}where n=\sum_{i=1}^{k}f_i4.5 SL and HL
Probability of an event A
\mathrm{P}(A)=\frac{n(A)}{n(U)}Complementary events
\mathrm{P}(A)+\mathrm{P}(A')=1Photon note“At least one” questions: 1-\mathrm P(\text{none}).
4.6 SL and HL
Combined events
\mathrm{P}(A\cup B)=\mathrm{P}(A)+\mathrm{P}(B)-\mathrm{P}(A\cap B)Mutually exclusive events
\mathrm{P}(A\cup B)=\mathrm{P}(A)+\mathrm{P}(B)Photon noteMutually exclusive means \mathrm P(A\cap B)=0. That is not the same as independent.
Conditional probability
\mathrm{P}(A|B)=\frac{\mathrm{P}(A\cap B)}{\mathrm{P}(B)}Independent events
\mathrm{P}(A\cap B)=\mathrm{P}(A)\,\mathrm{P}(B)Photon noteTo test for independence, check whether this holds with the given numbers.
4.7 SL and HL
Expected value of a discrete random variable X
\mathrm{E}(X)=\sum_{i=1}^{k}x_i\,\mathrm{P}(X=x_i)Photon noteA fair game has \mathrm E(\text{gain})=0.
4.8 SL and HL
Binomial distribution X\sim\mathrm B(n,p)
Photon noteFour conditions: fixed n, two outcomes, constant p, independent trials. State them when asked to justify the model.
Mean
\mathrm{E}(X)=npVariance
\mathrm{Var}(X)=np(1-p)Photon noteStandard deviation is the square root of this.
4.14 HL only
Linear transformation of a single random variable
\mathrm{E}(aX+b)=a\mathrm{E}(X)+bLinear combinations of n independent random variables, X_1,X_2,\dots,X_n
\mathrm{E}(a_1X_1\pm a_2X_2\pm\dots\pm a_nX_n)=a_1\mathrm{E}(X_1)\pm a_2\mathrm{E}(X_2)\pm\dots\pm a_n\mathrm{E}(X_n)Photon noteVariances always add, even when the variables are subtracted. And \mathrm{Var}(2X)\neq\mathrm{Var}(X_1+X_2).
Sample statistics. Unbiased estimate of population variance s_{n-1}^2
s_{n-1}^2=\frac{n}{n-1}s_n^24.17 HL only
Poisson distribution X\sim\mathrm{Po}(m)
Photon noteEvents occur singly, independently and at a constant average rate. Scale m to the time interval asked about.
Mean
\mathrm{E}(X)=mVariance
\mathrm{Var}(X)=mPhoton noteMean ≈ variance in the data suggests a Poisson model.
4.19 HL only
Transition matrices
\boldsymbol{T}^n\boldsymbol{s}_0=\boldsymbol{s}_nwhere \boldsymbol s_0 is the initial statePhoton noteThe steady state \boldsymbol s solves \boldsymbol{Ts}=\boldsymbol s, with entries adding to 1.
Not in the IB booklet · learn or derive these
Not in the AI booklet. Needed to find an unknown \mu or \sigma.
Every expected frequency should be at least 5; combine classes if not.
For a goodness of fit test: number of classes − 1 (minus any parameters estimated).
Topic 5: Calculus
5.3 SL and HL
Derivative of x^n
f(x)=x^n\Rightarrow f'(x)=nx^{n-1}Photon noteRewrite roots and fractions as powers first: \sqrt x=x^{1/2}, \dfrac1{x^2}=x^{-2}.
5.9 HL only
Derivative of \sin x
f(x)=\sin x\Rightarrow f'(x)=\cos xDerivative of \cos x
f(x)=\cos x\Rightarrow f'(x)=-\sin xDerivative of \tan x
f(x)=\tan x\Rightarrow f'(x)=\frac{1}{\cos^2x}Derivative of \mathrm e^x
f(x)=\mathrm{e}^x\Rightarrow f'(x)=\mathrm{e}^xDerivative of \ln x
f(x)=\ln x\Rightarrow f'(x)=\frac{1}{x}Chain rule
y=g(u),\ \text{where } u=f(x)\ \Rightarrow\ \frac{\mathrm{d}y}{\mathrm{d}x}=\frac{\mathrm{d}y}{\mathrm{d}u}\times\frac{\mathrm{d}u}{\mathrm{d}x}Product rule
y=uv\Rightarrow\frac{\mathrm{d}y}{\mathrm{d}x}=u\frac{\mathrm{d}v}{\mathrm{d}x}+v\frac{\mathrm{d}u}{\mathrm{d}x}Quotient rule
y=\frac{u}{v}\Rightarrow\frac{\mathrm{d}y}{\mathrm{d}x}=\frac{v\frac{\mathrm{d}u}{\mathrm{d}x}-u\frac{\mathrm{d}v}{\mathrm{d}x}}{v^2}5.5 SL and HL
Integral of x^n
\int x^n\,\mathrm{d}x=\frac{x^{n+1}}{n+1}+C,\quad n\neq-1Photon noteNever drop the +C on an indefinite integral.
5.8 SL and HL
The trapezoidal rule
\int_a^by\,\mathrm{d}x\approx\frac{1}{2}h\big((y_0+y_n)+2(y_1+y_2+\dots+y_{n-1})\big)where h=\dfrac{b-a}{n}Photon noten is the number of strips, so there are n+1 values of y. Concave-up curves give an overestimate.
5.11 HL only
Standard integrals
\int\frac{1}{x}\,\mathrm{d}x=\ln|x|+C5.12 HL only
Area of region enclosed by a curve and x or y-axes
A=\int_a^b|y|\,\mathrm{d}x\quad\text{or}\quad A=\int_a^b|x|\,\mathrm{d}yVolume of revolution about x or y-axes
V=\int_a^b\pi y^2\,\mathrm{d}x\quad\text{or}\quad V=\int_a^b\pi x^2\,\mathrm{d}y5.13 HL only
Acceleration
a=\frac{\mathrm{d}v}{\mathrm{d}t}=\frac{\mathrm{d}^2s}{\mathrm{d}t^2}=v\frac{\mathrm{d}v}{\mathrm{d}s}Photon noteUse v\dfrac{\mathrm dv}{\mathrm ds} when acceleration is given in terms of displacement.
Distance travelled from t_1 to t_2
\text{distance}=\int_{t_1}^{t_2}|v(t)|\,\mathrm{d}tDisplacement from t_1 to t_2
\text{displacement}=\int_{t_1}^{t_2}v(t)\,\mathrm{d}t5.16 HL only
Euler's method
y_{n+1}=y_n+h\times f(x_n,y_n);\quad x_{n+1}=x_n+hwhere h is a constant (step length)Euler's method for coupled systems
x_{n+1}=x_n+h\times f_1(x_n,y_n,t_n),\quad y_{n+1}=y_n+h\times f_2(x_n,y_n,t_n),\quad t_{n+1}=t_n+hwhere h is a constant (step length)5.17 HL only
Exact solution for coupled linear differential equations
\boldsymbol{x}=A\mathrm{e}^{\lambda_1t}\boldsymbol{p}_1+B\mathrm{e}^{\lambda_2t}\boldsymbol{p}_2Photon note\lambda_1,\lambda_2 are the eigenvalues and \boldsymbol p_1,\boldsymbol p_2 the eigenvectors of the system's matrix.
Not in the IB booklet · learn or derive these
Maximum or minimum: check the sign of f' either side, or use the graph on the calculator.
Negative real parts: stable. Purely imaginary eigenvalues: closed loops (centre).
Rewrite as a coupled system, then use Euler's method or eigenvalues.
Source: IB Mathematics: applications and interpretation HL formula booklet, first examinations 2021, version 1.0 (SL lines checked against the SL booklet, version 1.0), retyped by Photon Resources. This is an unofficial study companion, not produced or endorsed by the International Baccalaureate. In the exam you use the clean official booklet your school provides. All notes and extra formulas are ours.